Reach is a three-dimensional problem
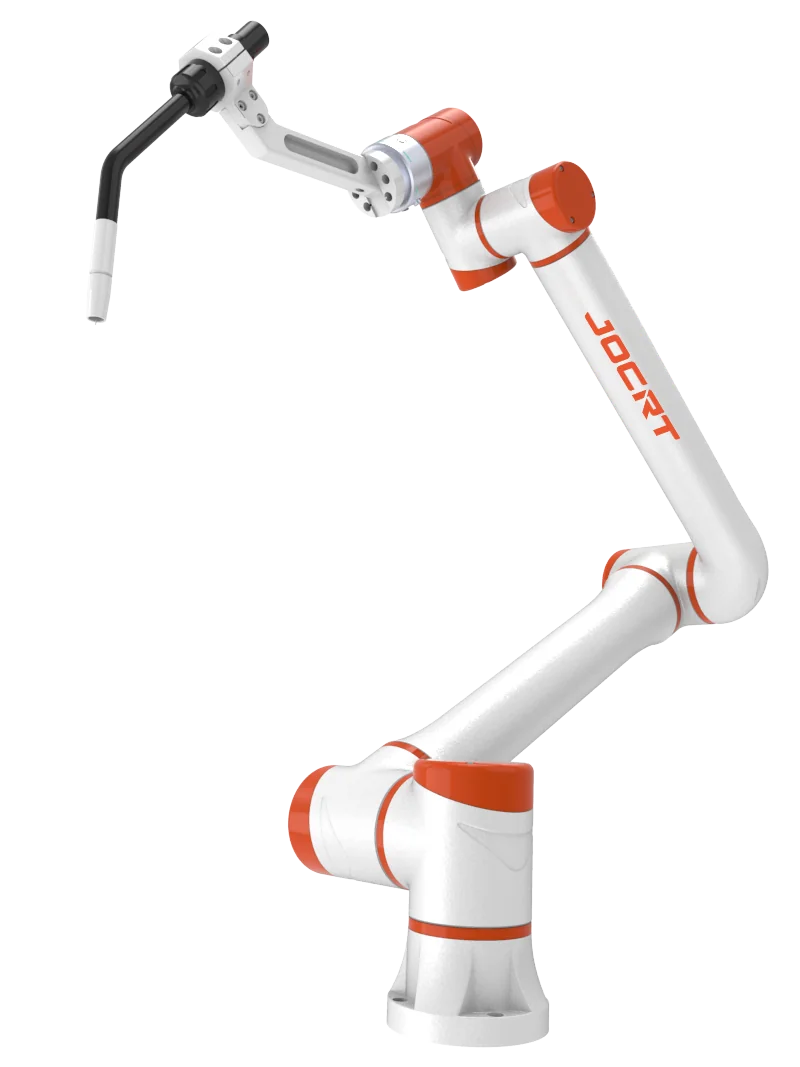
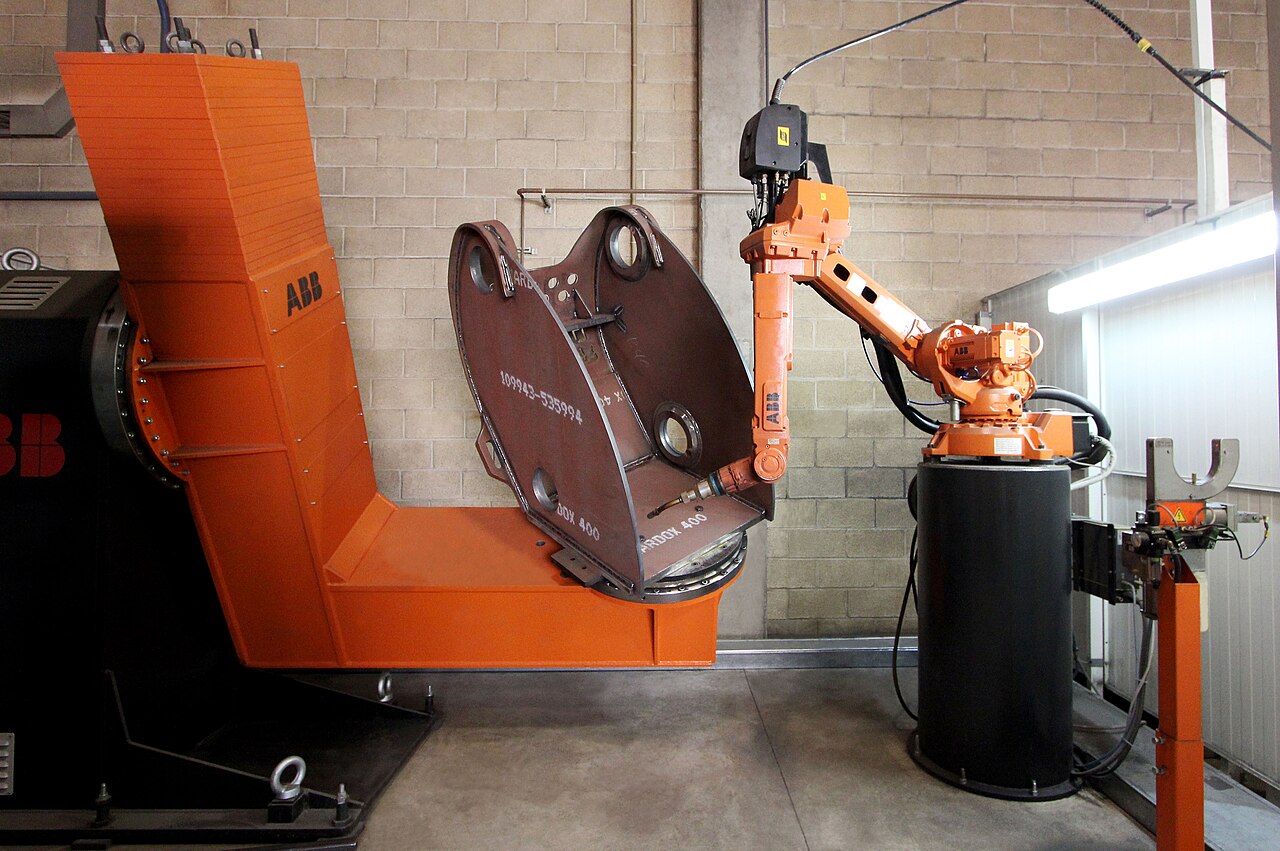
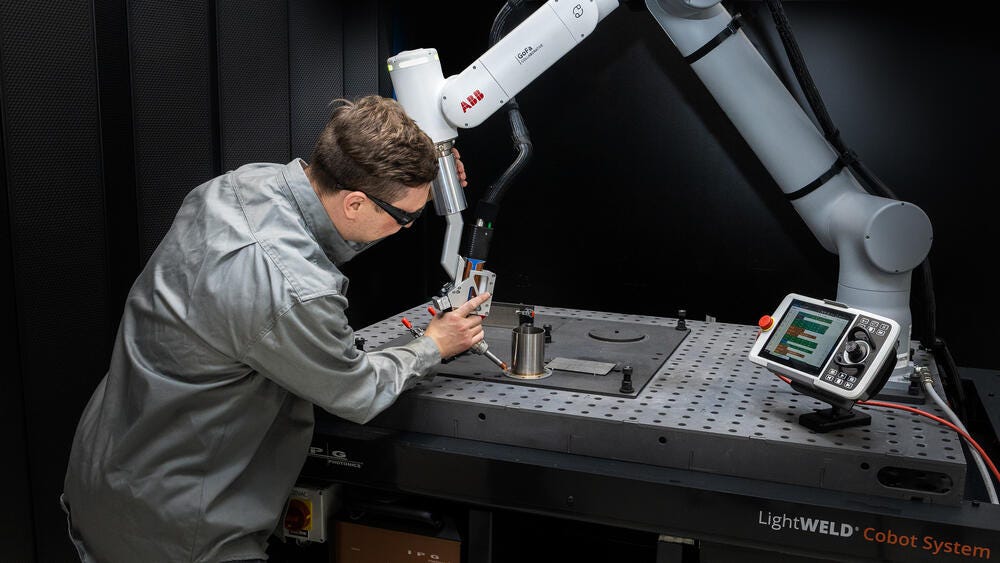
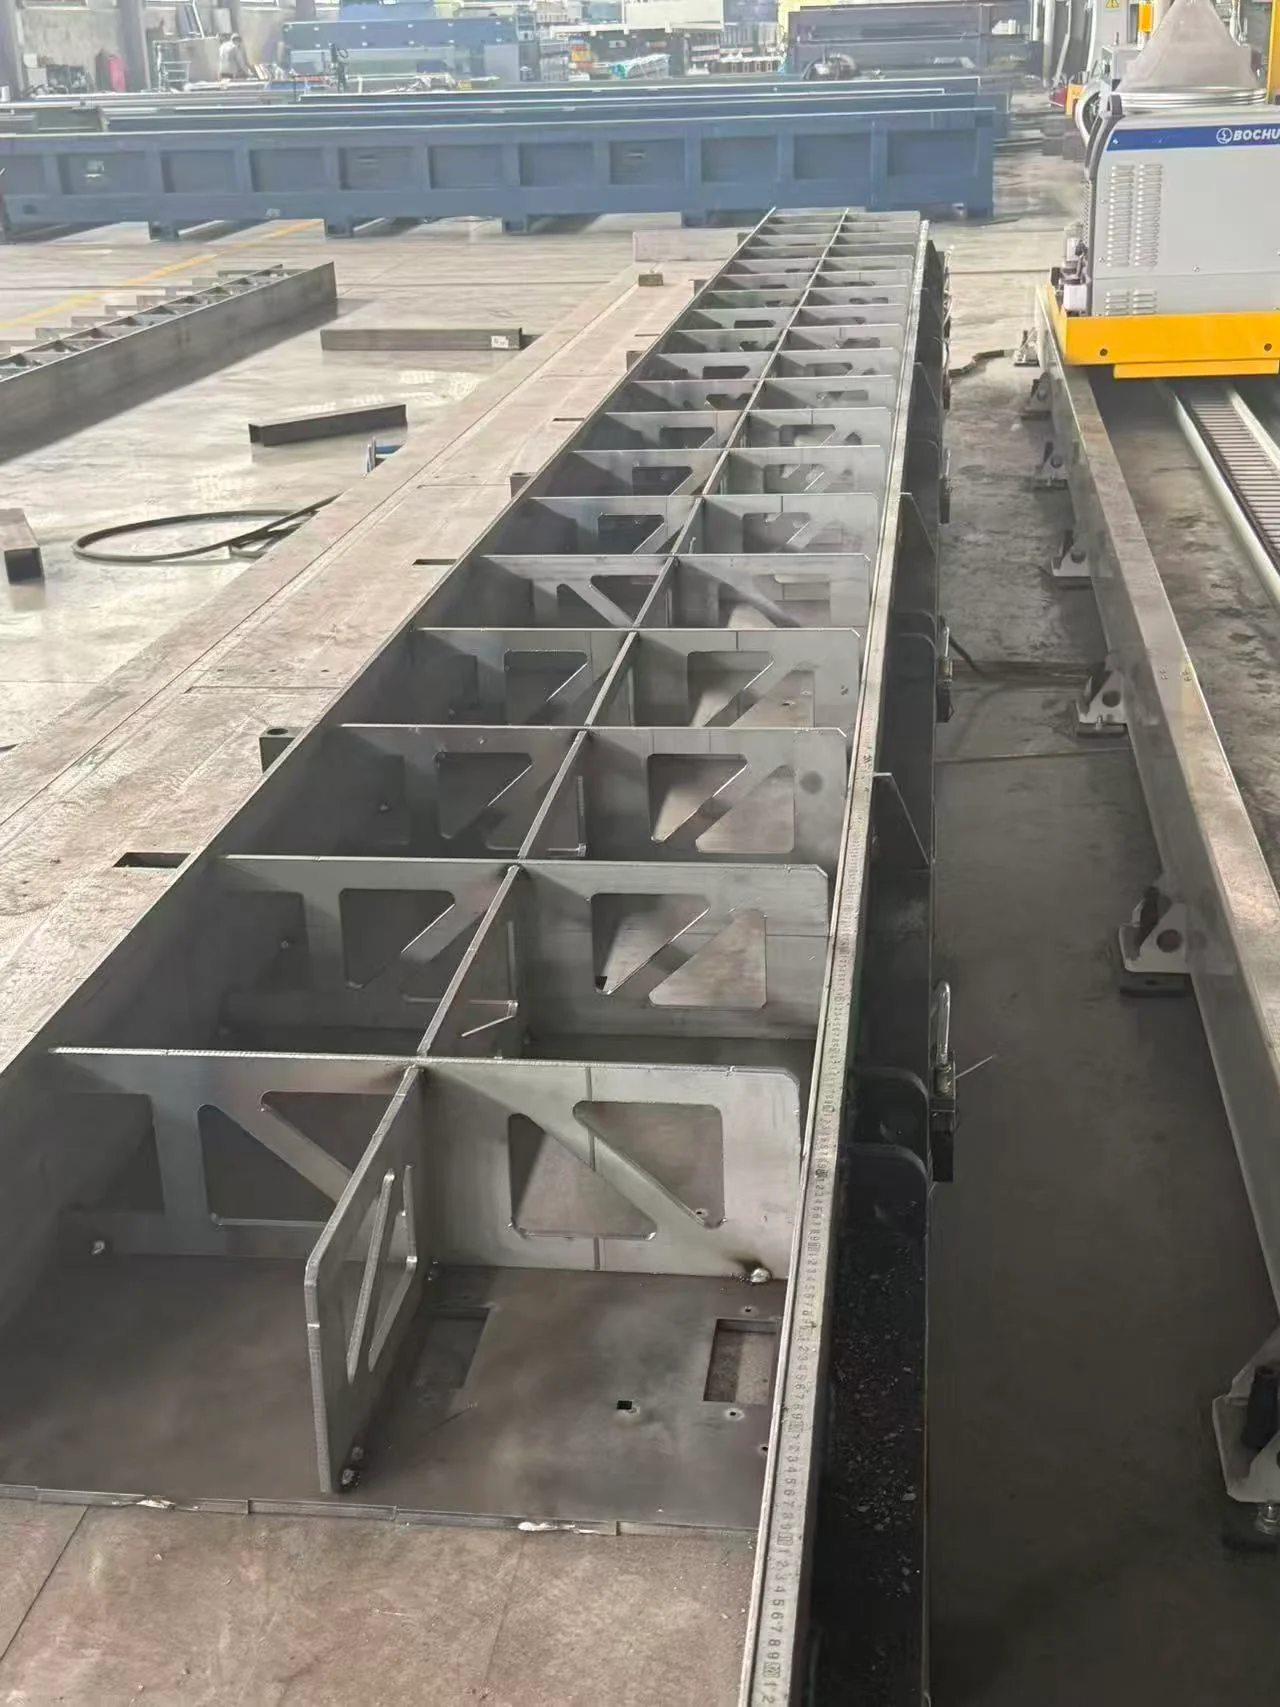
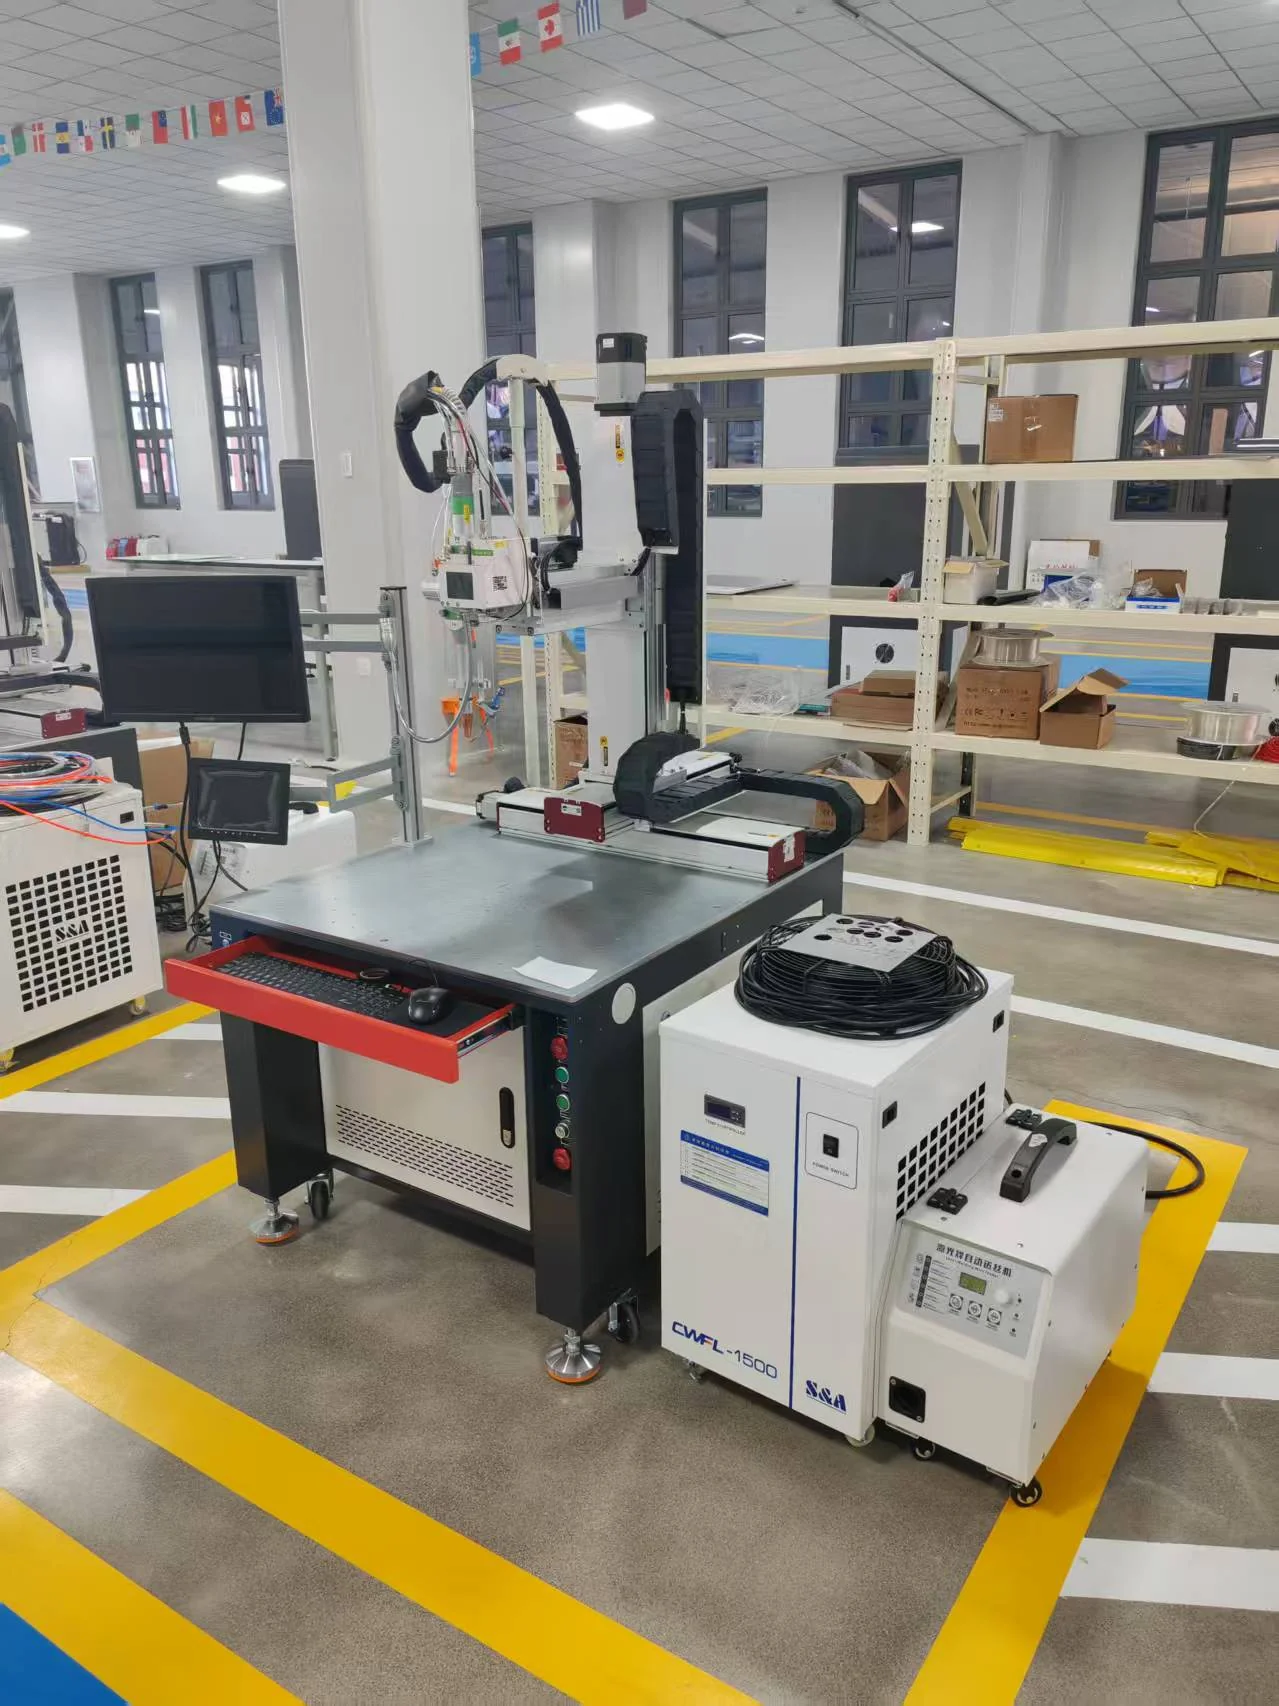
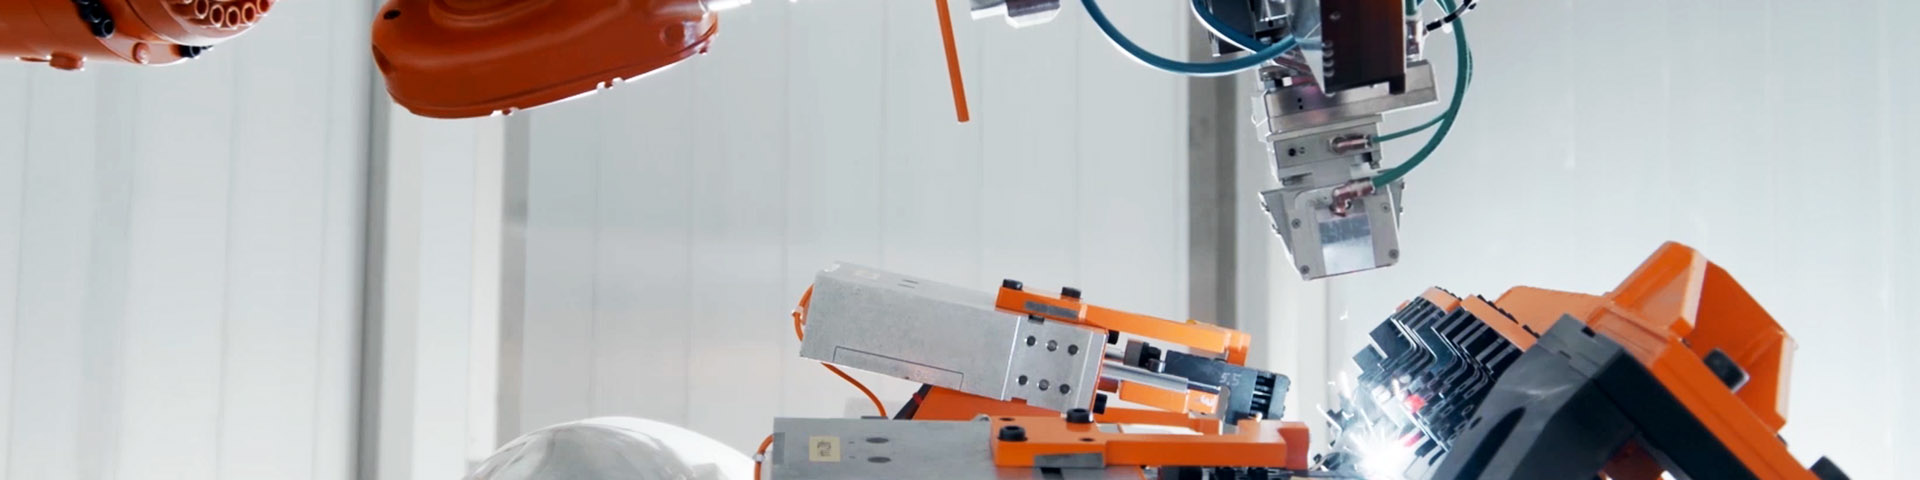
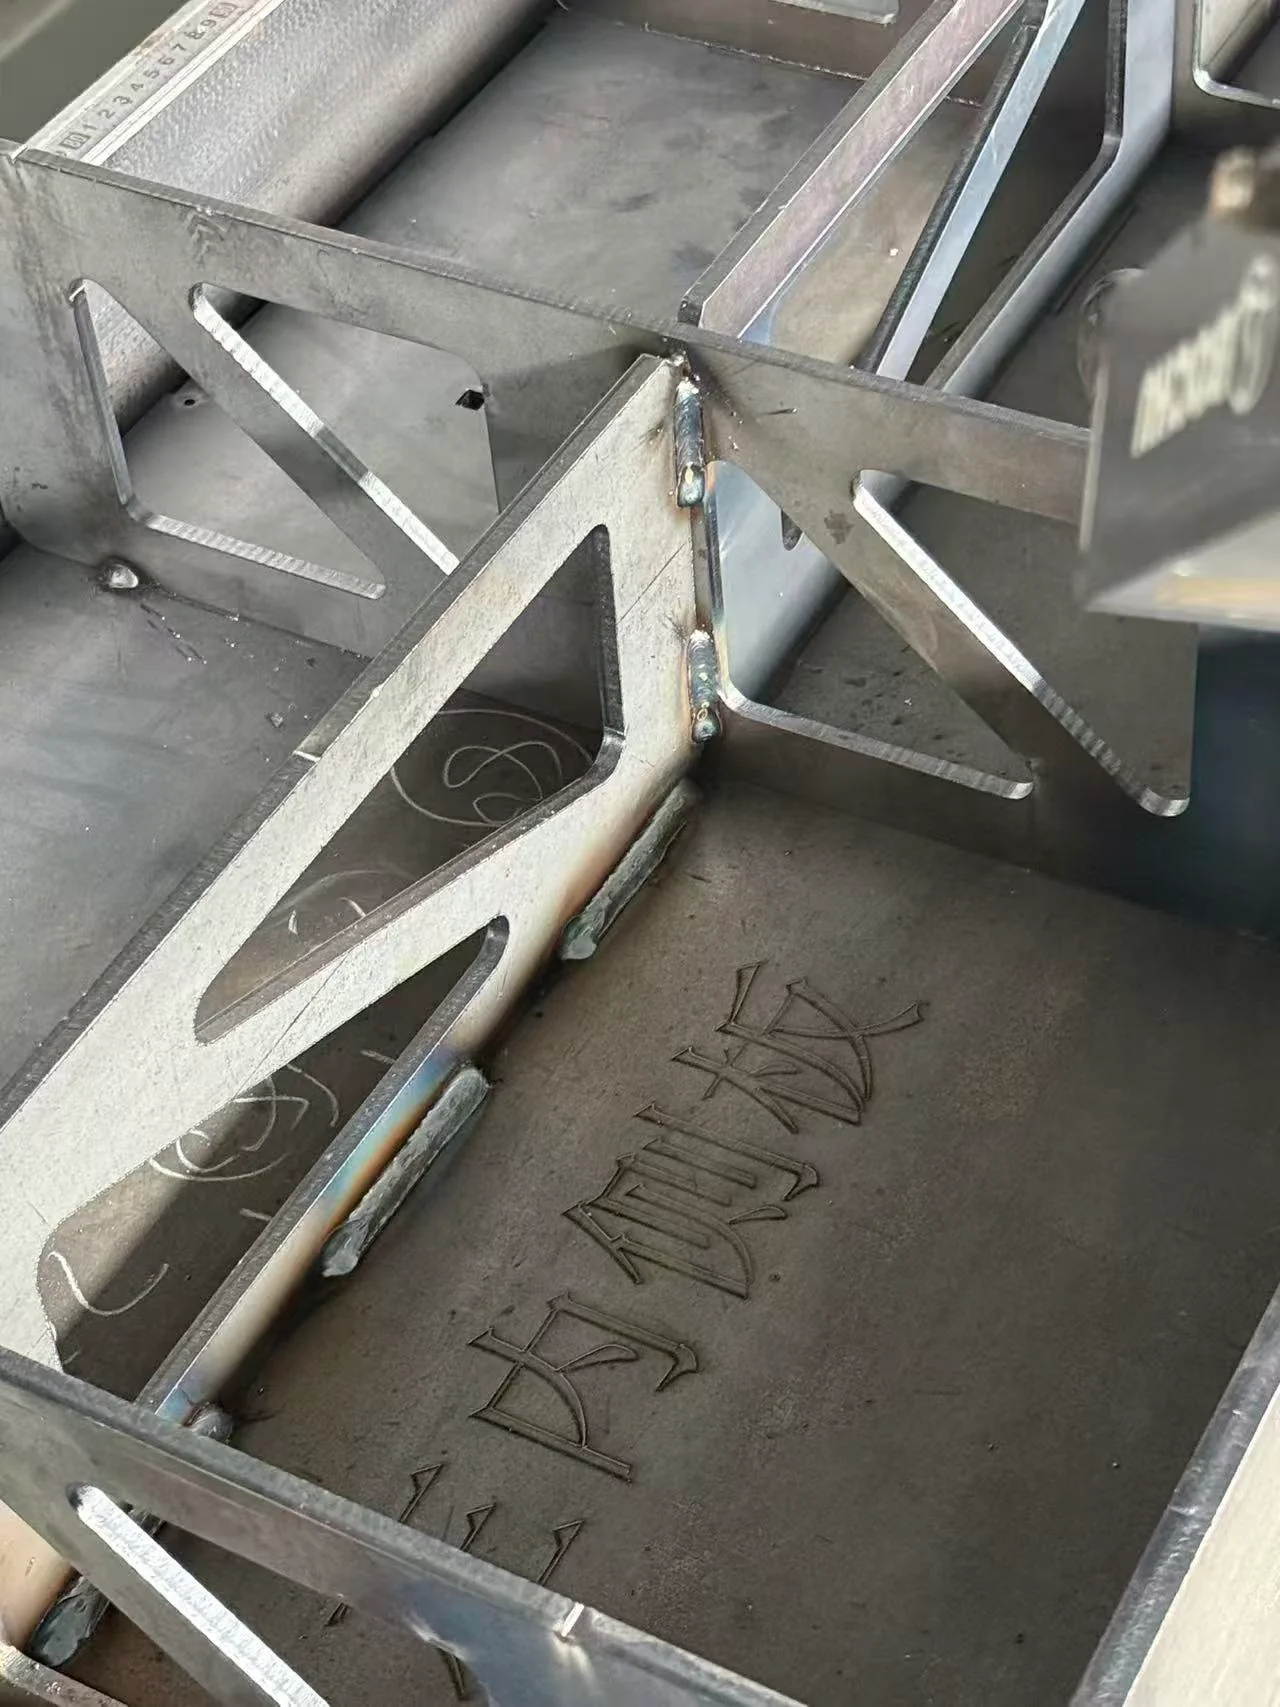
A nominal reach radius does not show whether the robot can hold the required tool angle at every point. The head or torch, cable package, clamps and part geometry may restrict access. Evaluate approaches and transitions as well as the welding path itself.
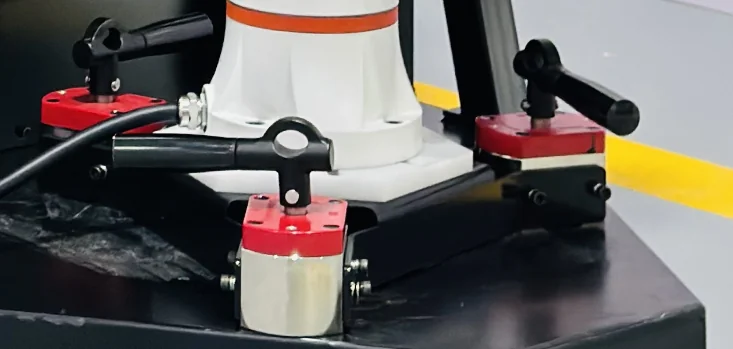
A seam near the edge of the working envelope can force an awkward arm posture even if the tool reaches its endpoints. During the connecting path, individual joints may approach movement limits or require rapid changes. Moving the fixture or changing the part orientation can be more effective than adding reach without reviewing the actual path. Cable clearance must also remain usable through the full movement, including the return to the loading position.